The Open Robot Company

Full Rig

More modalities. Richer data.

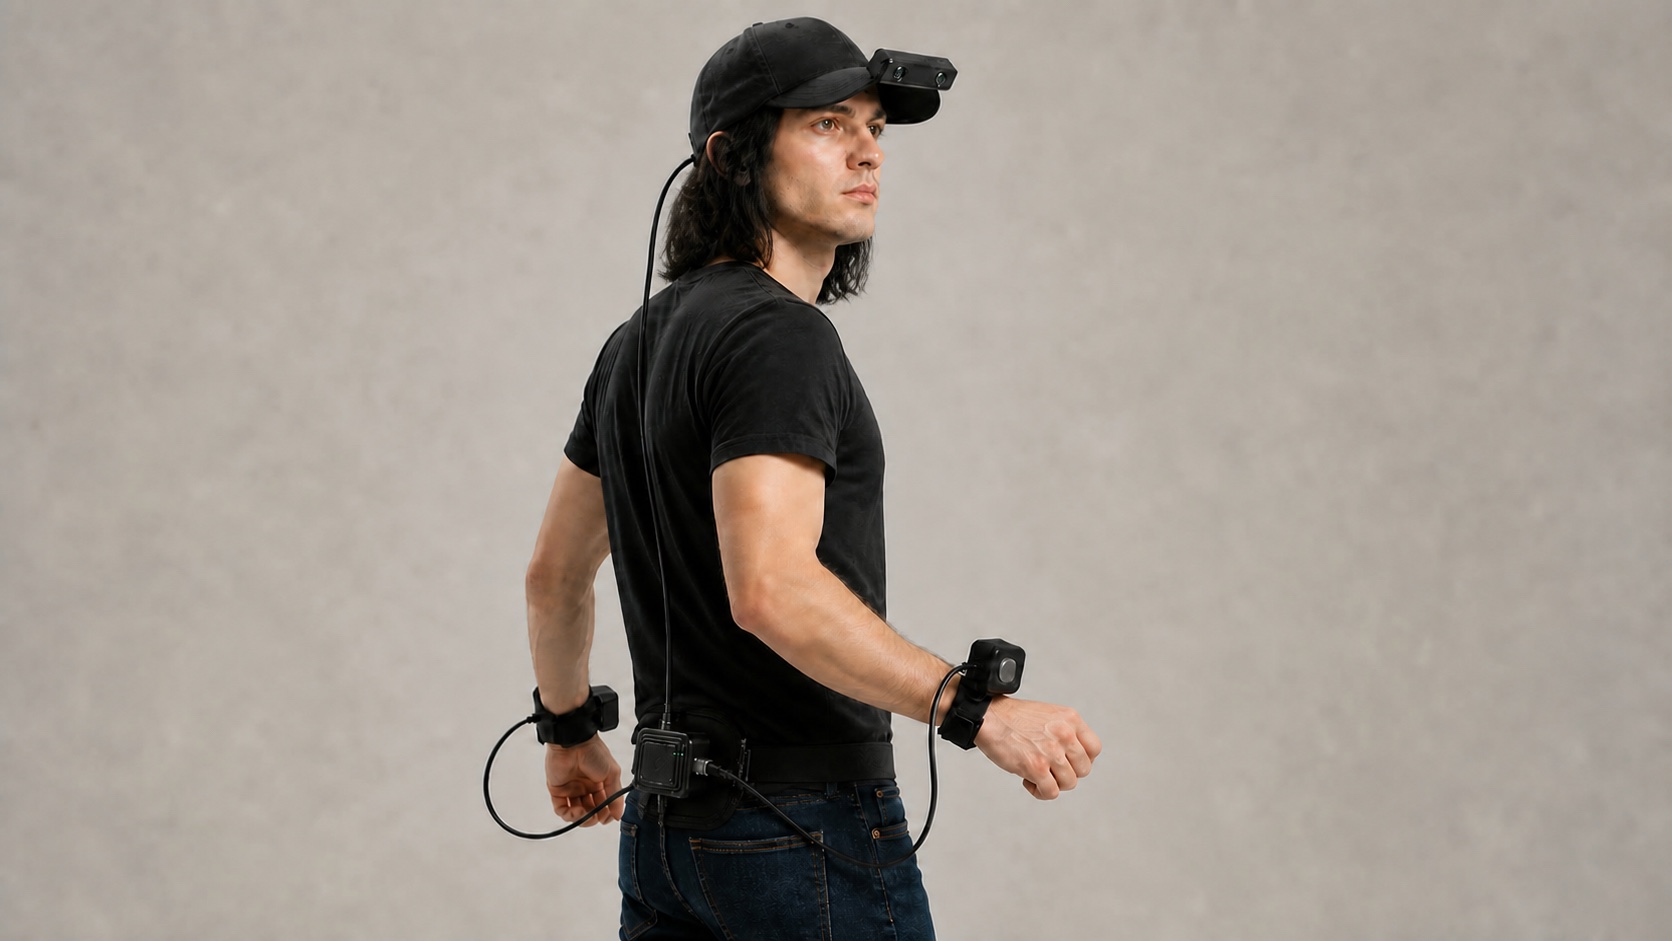
Head-mounted stereo plus a global-shutter camera on each wrist, hardware-triggered on one receiver. Scene view and wrist views in one episode, with IMU and sensor events on the same clock.

Discuss hardware partnerships
  1. 01Stereo · head view
  2. 02Mono module · left wrist view
  3. 03Mono module · right wrist view
OpenRobot Full Rig with Stereo head camera, two wrist-mounted Mono cameras, and a back-mounted shared receiver

Select a camera to open its spec

RGB streams4
Receiver1
Capture30 fps
SyncHardware trigger

Real episode · soldering

See what the rig sees.

Hardware triggered

00:00.000 / 01:03.967
SyncHardware trigger
Wrist-to-wrist offset24 µs median
Dropped frames0
IMU≈505 Hz

Capture modes

Do all views need the same timestep?

Hardware sync when observations across cameras must be co-timed exactly. Independent capture when aligning on per-frame timestamps afterwards is enough.

Yes Hardware synchronized Recommended

Every camera exposes on the same trigger.

One trigger line drives Stereo and both Mono camera modules. Global shutters, so exposures align to the pulse, not to a rolling readout.

Across the rig
30 fps
Measured wrist delta
24 µs median
Use when
Handovers, bimanual, contact-rich tasks
No Independent capture

Each camera runs on its own clock.

No trigger cable. Streams are aligned afterwards from per-frame device timestamps.

Mono module capture
Up to 60 fps free-running
Cross-camera alignment
Device timestamps
Use when
Sub-frame timing is not required

Synchronized output

Every signal. One timeline.

01 / Vision 4 RGB streams · 30 fps

Stereo 3840 × 1200 side-by-side
2 × Mono 1920 × 1200

02 / Motion ≈505 Hz IMU

6-axis, on the same clock as every frame.

03 / Sensors GPIO event timestamps

Bring external triggers and sensor events onto the same clock.

Per-stream specification

What each camera records.

Stereo-cap numbers are the approved public spec. Mono numbers are the current wrist module. Lenses are M12 pinhole and can be swapped for a different field of view on request.

Spec Stereo-cap · head view Mono module · each wrist view
Sensor2 × color global-shutter cameras, 1/2.6", 1928 × 1208 active, 3 µm pixelsGlobal shutter
Resolution1920 × 1200 per eye · 3840 × 1200 side-by-side1920 × 1200
Frame rate30 fps30 fps hardware-synchronized · up to 60 fps free-running
ShutterGlobal · hardware same-frame exposure, 0 µs left/right offset over 23,023 framesGlobal
Field of view≈112° H · 80° V (±3°) · 119° D≈112° H · 80° V (±3°) · 119° D
LensM12 pinhole, ultra-wide · customizableM12 pinhole · customizable
Stereo baseline≈60 mm—
Motion6-axis IMU ≈505 Hz, ±1000 dps, ±4 g · ≈0.4 ms video-to-IMU alignment—
TimestampsPer-frame hardware sync timestamps, device microsecondsPer-frame device timestamps
Cross-camera syncOne shared hardware trigger across the rig · 24 µs median wrist-to-wrist offset · 0 dropped frames in tested sessions
CalibrationPer-eye intrinsics + stereo extrinsics · pinhole + Brown-Conrady · ≈0.36 px stereo reprojection RMSPinhole + Brown-Conrady intrinsics on request
InterfaceUSB 2.0 High-Speed UVC to the OpenRobot receiver
RecordingLocal to the receiver · bring your own compatible removable SD storage and USB power bank · phone control over Bluetooth and 2.4 GHz Wi-Fi · no laptop in the capture loop

Full Rig sample

Validate on your task before scaling.

Request Full Rig