The Open Robot Company

Capture systems for research programs

Capture the views your model needs.

Choose six head-mounted views, synchronized head-and-wrist capture, or a compact stereo system. We support sample validation, sensor adaptation, and deployment for data-collection programs.

Modular capture systems

Start with the capture topology.

  • Global-shutter cameras with hardware timestamps.
  • One OpenRobot receiver across every system.
  • Bring your own compatible removable SD storage and USB power bank.
  • Adaptable optics and mounting for data-collection programs.
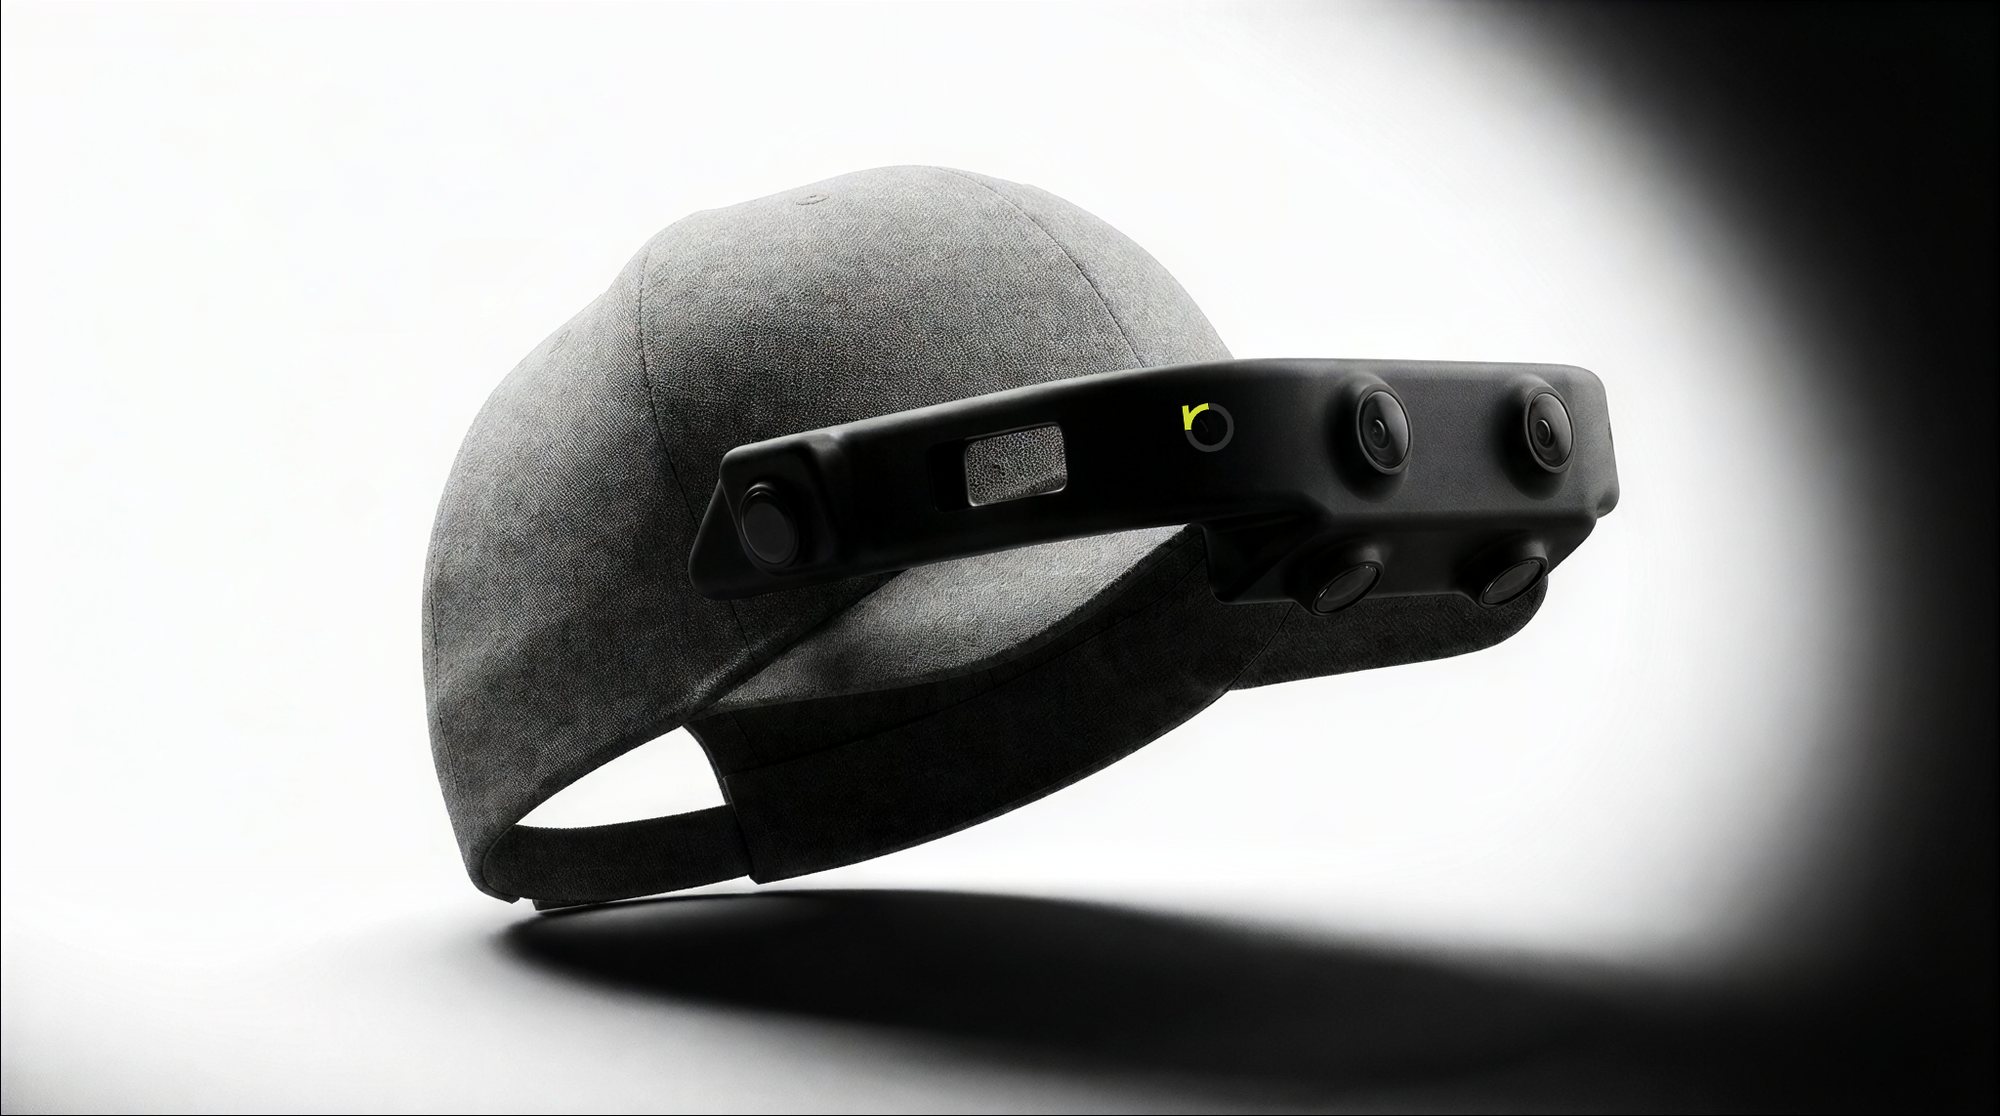
Three-quarter view of the OpenRobot Six-camera cap
Six-camera capSample program

Scene, hands, and periphery from the head.

Two forward, two downward, and two side cameras capture six head-mounted views without wrist hardware.

Topology
2 forward + 2 downward + 2 side
Sensor
6 global-shutter RGB cameras
Resolution
1920 × 1200 per stream
Synchronized mode
All six at 30 fps on one trigger
Lens / field of view
M12; approximately 112° H / 80° V (±3°) / 119° D
Motion
2 × 6-axis IMU at approximately 505 Hz
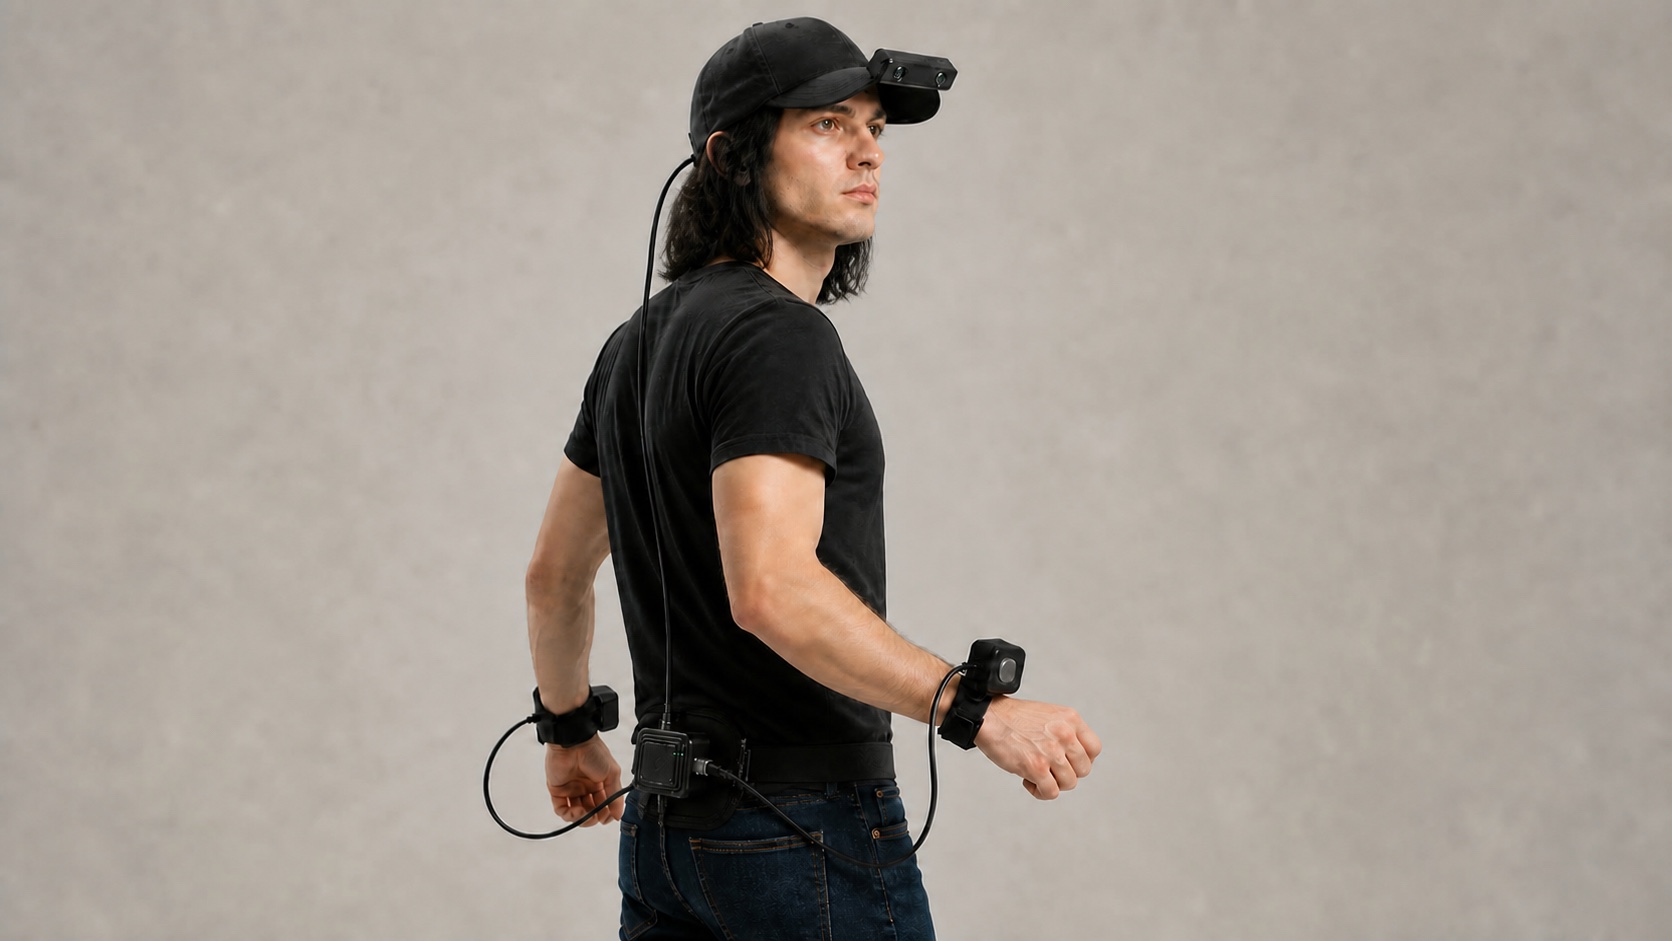
Operator wearing the Full Rig with Stereo-cap and a Mono camera module on each wrist
Full RigSample ready

Head and wrist views on one clock.

Stereo scene context plus a global-shutter camera on each wrist for hand-object interaction.

Topology
2 head + 2 wrist RGB streams
Sensor
Global shutter at each wrist
Resolution
1920 × 1200 per stream
Synchronized mode
All four at 30 fps on one trigger
Lens / field of view
M12; approximately 112° H / 80° V (±3°) / 119° D
Measured timing
24 µs median wrist-to-wrist offset
Three-quarter view of the OpenRobot Stereo-cap
Stereo-capStock / Sample ready

Synchronized stereo from the head.

A compact head-mounted system for spatial scene context, close-range manipulation, and calibrated stereo processing.

Topology
2 head-mounted RGB streams
Cameras
2 color global-shutter cameras
Resolution
1920 × 1200 per eye
Synchronized mode
Both eyes at 30 fps on one trigger
Lens / field of view
M12; approximately 112° H / 80° V (±3°) / 119° D
Motion
6-axis IMU at approximately 505 Hz

Storage Bring your own compatible removable SD card

Power Bring your own compatible USB power bank

Front view Front view of the OpenRobot Stereo-cap on a white mannequin
Three-quarter view Three-quarter view of the OpenRobot Stereo-cap and dual-camera module

Stereo-cap

Our stock spatial capture system for dexterous, close-range work.

Vision
2 global-shutter cameras
Capture
3840 × 1200 side-by-side @ 30 fps
Per eye
1920 × 1200 @ 30 fps
Field of view
Approximately 112° H / 80° V (±3°) / 119° D
Motion
6-axis IMU at approximately 505 Hz
Sync
Hardware left/right sync with camera–IMU timestamps
Storage
Bring your own compatible removable SD card
Capture flow
Records locally to the receiver; phone control over Bluetooth and 2.4 GHz Wi-Fi
Power
Bring your own compatible USB power bank

Mono camera module

The global-shutter wrist camera used by Full Rig, available for task-specific mounting.

Sensor
Global shutter
Capture
1920 × 1200 at 30 fps synchronized
Fast-motion mode
Up to 60 fps free-running
Lens / field of view
M12; approximately 112° H / 80° V (±3°) / 119° D
Mounting
Wrist, tool, or fixed fixture

Next senses

The hardware roadmap.

ContactR&D

Touch and force.

Tactile gloves, sensors, and future contact surfaces.

Custom sensorPartner

Your modality.

Co-designed around your environment, form factor, and deployment.